Technical specifications
Specifications for the XTac UMI G1 grippers, the tracking system and the backpack. Wiring is in Gripper connection and serial numbers; choosing between the editions is in Product line and configuration comparison.
Leader gripper
| Parameter | Specification |
|---|---|
| Structure | Two-finger gripper, one left and one right |
| Dimensions | 145 × 186 × 170mm |
| Weight | About 370g |
| Payload | 2.5kg maximum |
| Opening travel | 0–150mm (each unit's calibrated value applies) |
| Visuotactile sensors | 2 (one per finger), see Visuotactile sensor below |
| Wrist fisheye camera | 190° field of view, 640 × 480 @ 30fps |
| IMU | 9-axis, 100Hz |
| Opening encoder | 100Hz |
| Connector and power | USB Type-C (locking), DC 5V / 500mA bus power, no internal battery |
| Operating temperature | 0–50°C |
Visuotactile sensor
The fingertip sensor is Xense's GS-PS visuotactile sensor; see the product page.
| Parameter | Specification |
|---|---|
| Imaging | Tri-color illumination |
| Sensing area | 623mm² |
| Elastomer thickness | 2–5mm |
| Image resolution | 640 × 480 |
| Sampling rate | 0–120Hz |
| Range | 0–25N |
| Force accuracy | 0.2N |
| Deformation accuracy | 0.1mm |
| Modalities | 3D shape, 6-axis force, 3D force distribution, slip detection |
The frame rate used during collection can be set as needed (the Developer Kit records tactile at 30fps by default) without changing the sensors' own specification.
Follower gripper
| Parameter | Specification |
|---|---|
| Structure | Two-finger gripper, mounted on the robot's end effector |
| Dimensions | 200 × 157 × 111mm (L × W × H), see the drawing below |
| Motor | RobStride EL05 |
| Maximum output torque | 1.1N·m |
| Opening angle | 0–70° |
| Control | Impedance control (default), force-position control |
| Connector and power | USB Type-C for communication + 24V power adapter (24V 2.5A) |
| Operating temperature | 0–50°C |
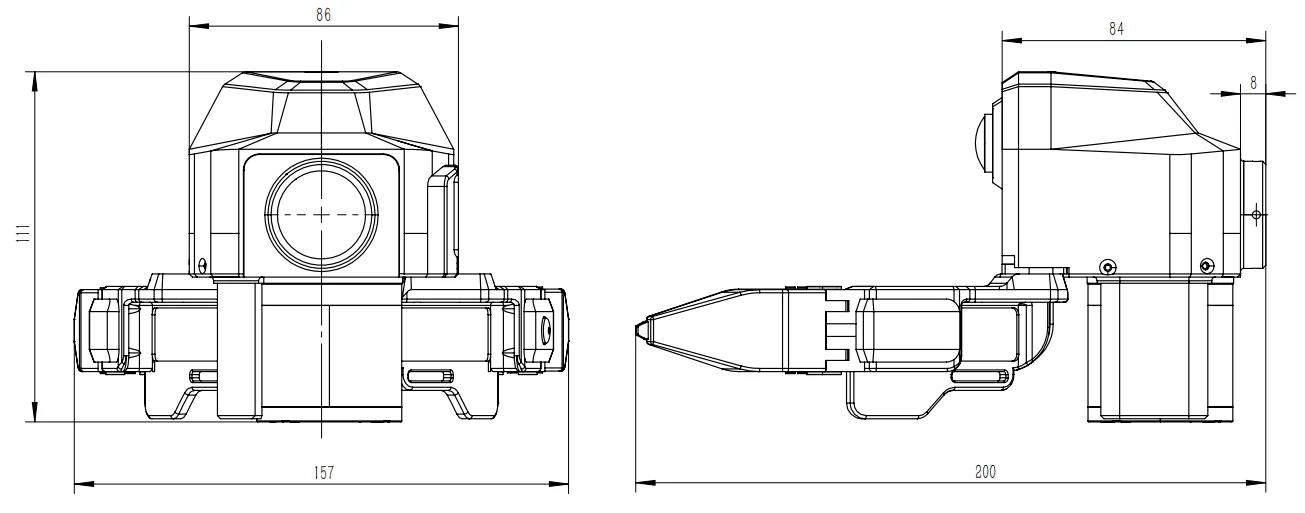
How to use it is in Follower gripper overview; the flange interface, frames and 3D models are in XTac-UMI-Description.
Tracking and synchronization
| Parameter | Specification |
|---|---|
| Pose source | Pico4 Ultra Enterprise headset + trackers, 6-DoF |
| Pose rate | About 90Hz on the Developer Kit; every pose the headset reports is recorded on the Backpack Kit |
| Positioning accuracy | < 3mm |
| Multi-device time sync | 5ms |
| Coordinate frame | X forward, Y left, Z up, see Coordinate frames |
The backpack
The Backpack Kit's collection unit: the grippers and headset plug into it and the console opens in a browser. See The XTac UMI Backpack.
| Parameter | Specification |
|---|---|
| Processor | RK3588 |
| Storage | eMMC system disk + 1TB NVMe data disk; recordings and exports live on the data disk |
| Disk-full rule | The data disk counts as full at 80% and recording stops |
| Exported data size | About 0.5GB per hour of exported LeRobot dataset |
| Power | 12V 3A power adapter, or a 20000mAh power bank through a 12V PD power cable |
| Power draw | About 20W |
| Power-bank runtime | About 3.5–4 hours |
| Network | Ethernet; Wi-Fi (5GHz); built-in 5GHz hotspot |
| Ports | UMI-L / UMI-R for the leader grippers, PICO for the headset, DC IN for power, HOST1 / HOST2 USB host ports, plus Ethernet, TF slot, HDMI and headphone jack, see Connectors |
| Operating temperature | 0–40°C |
| Environment | Indoor use; not waterproof, keep away from rain, splashes and heavy dust |
The serial number, hotspot name and password on the body label are explained in Identifying the unit: by its label, not by IP.