XTac UMI · Wearable multimodal data collection
Give robot datasets
a sense of touch
Two-handed touch, vision and pose in sync
One demonstration, a training-ready dataset
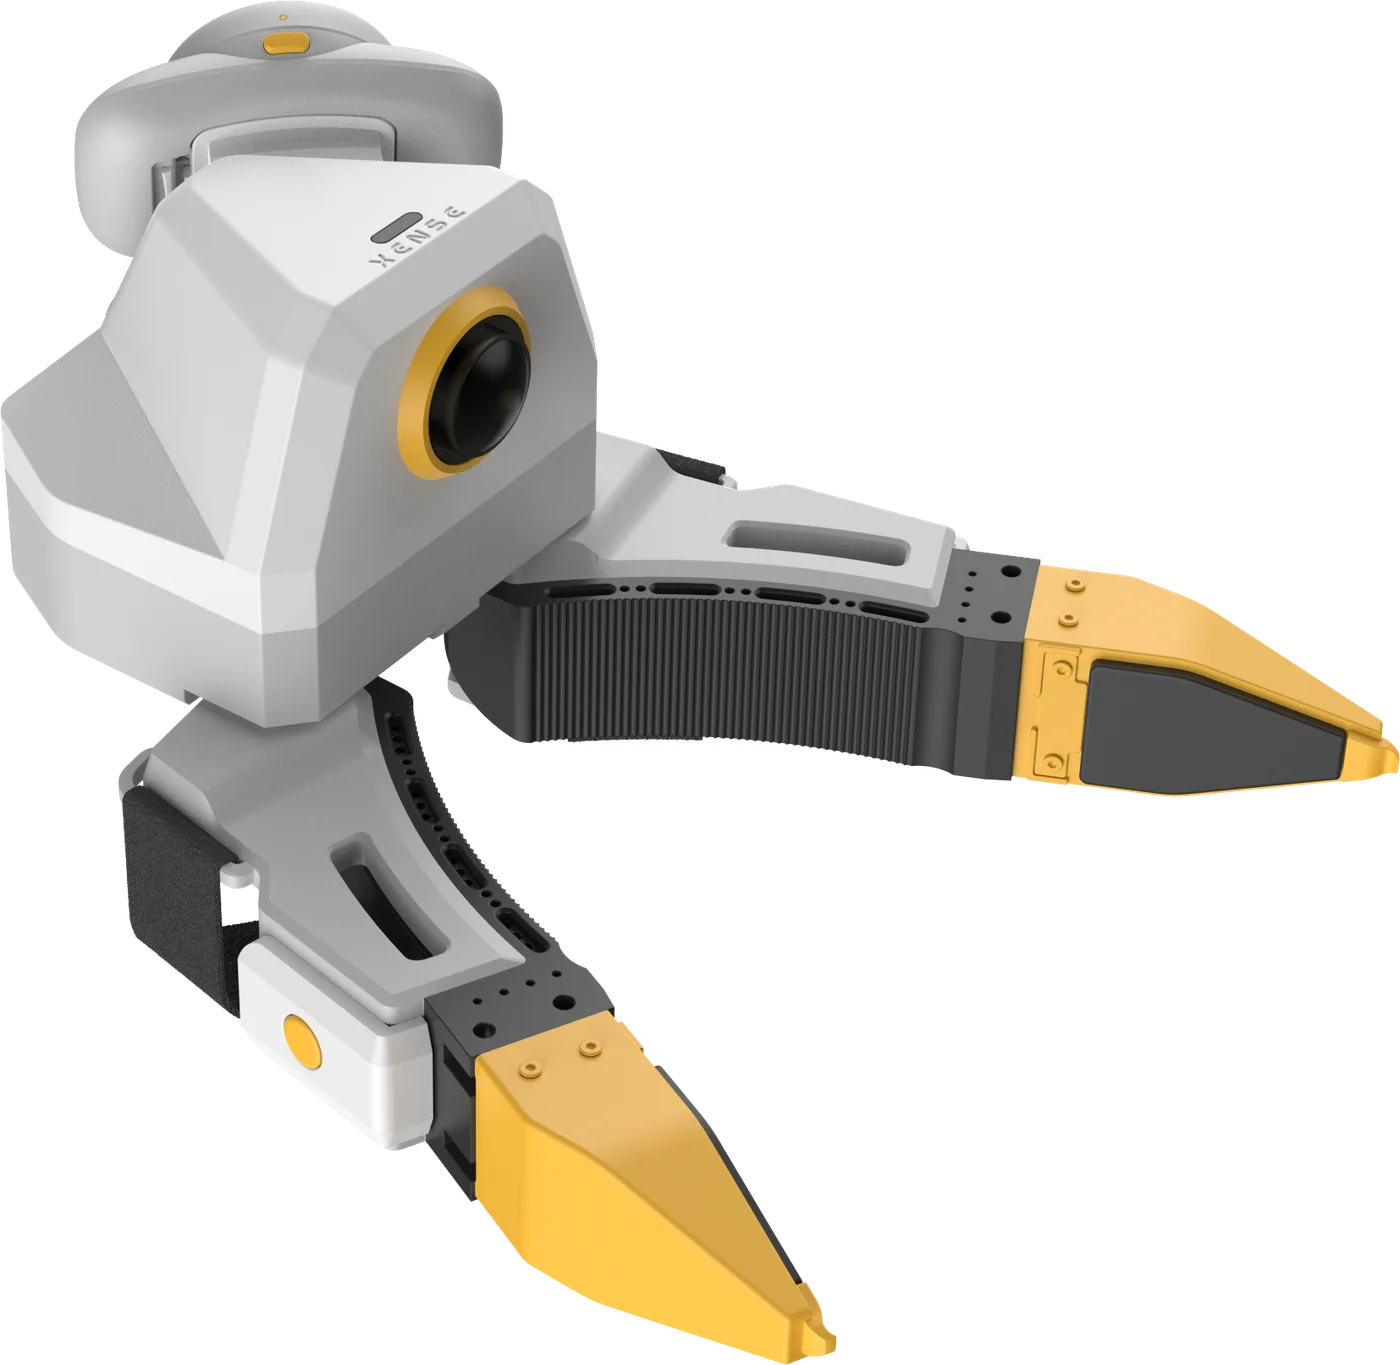
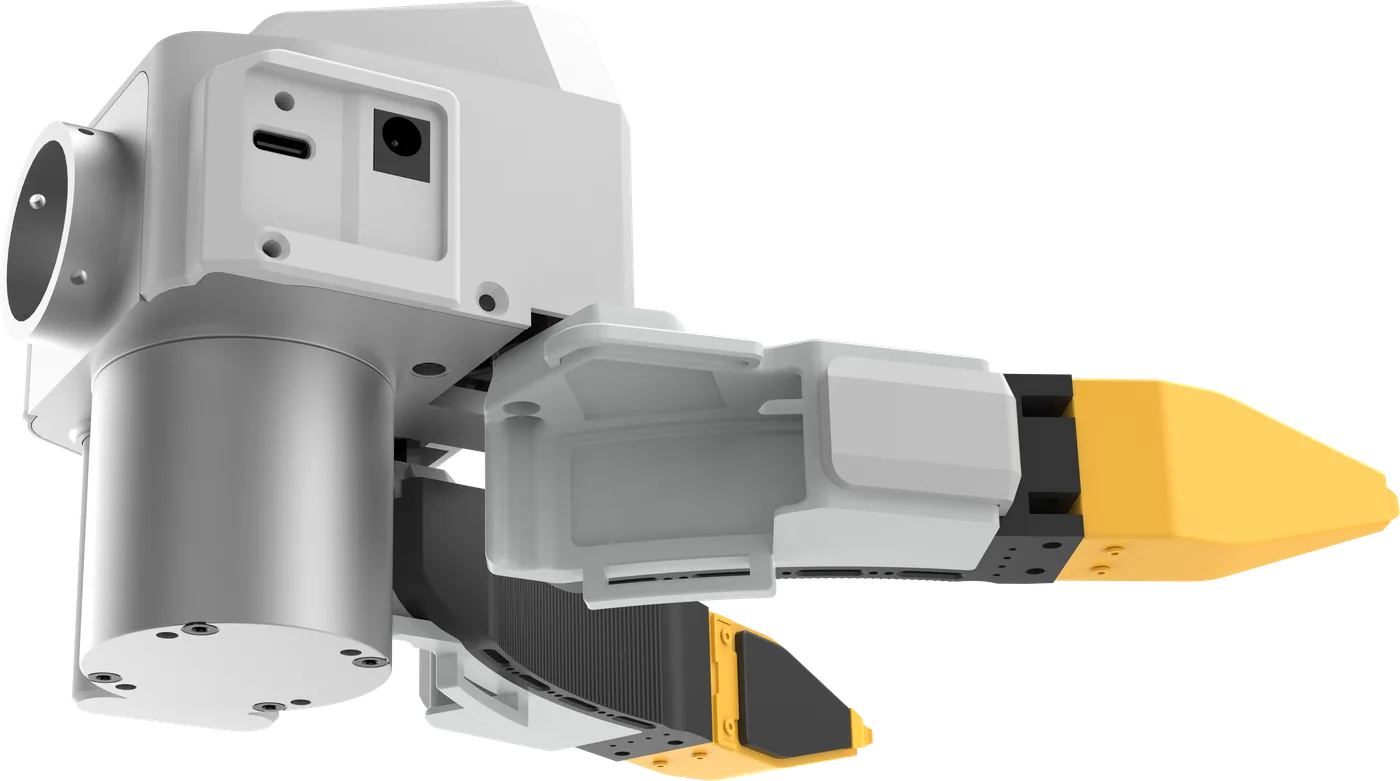
XTac UMI G1 grippers with the Pico4 Ultra Enterprise headset
in a Backpack Kit or a Developer Kit


Touch Ignites Physical Intelligence
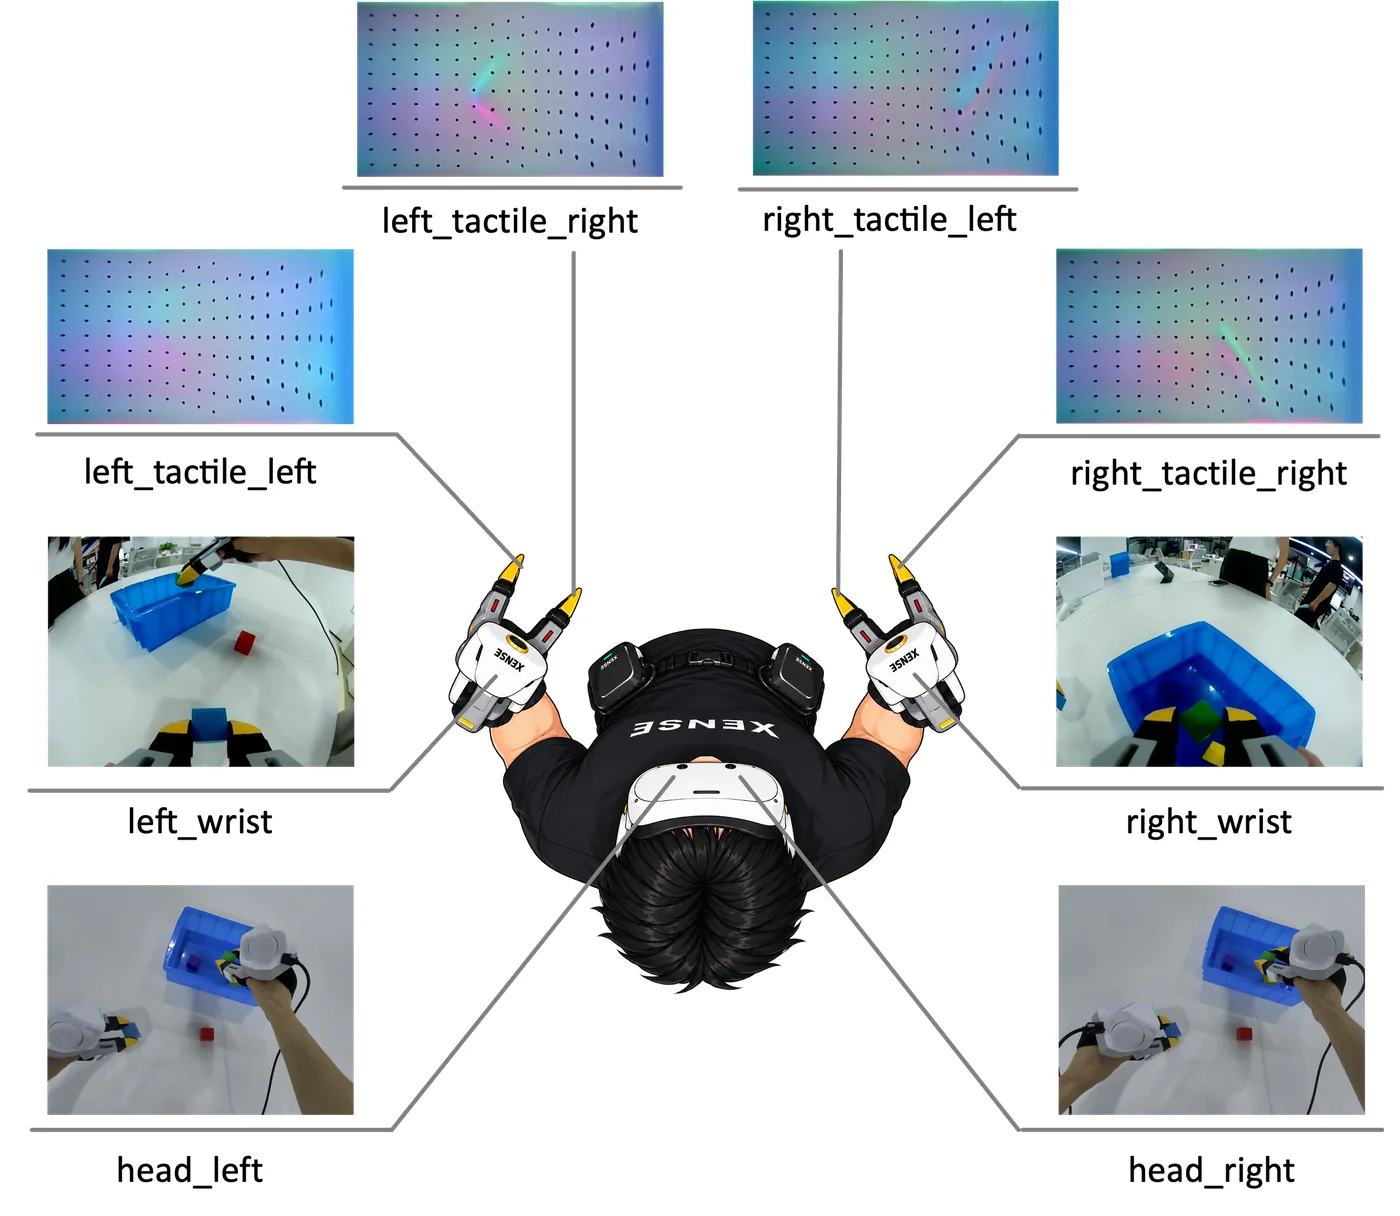
8 image streams 4 tactile + 2 wrist + 2 headset
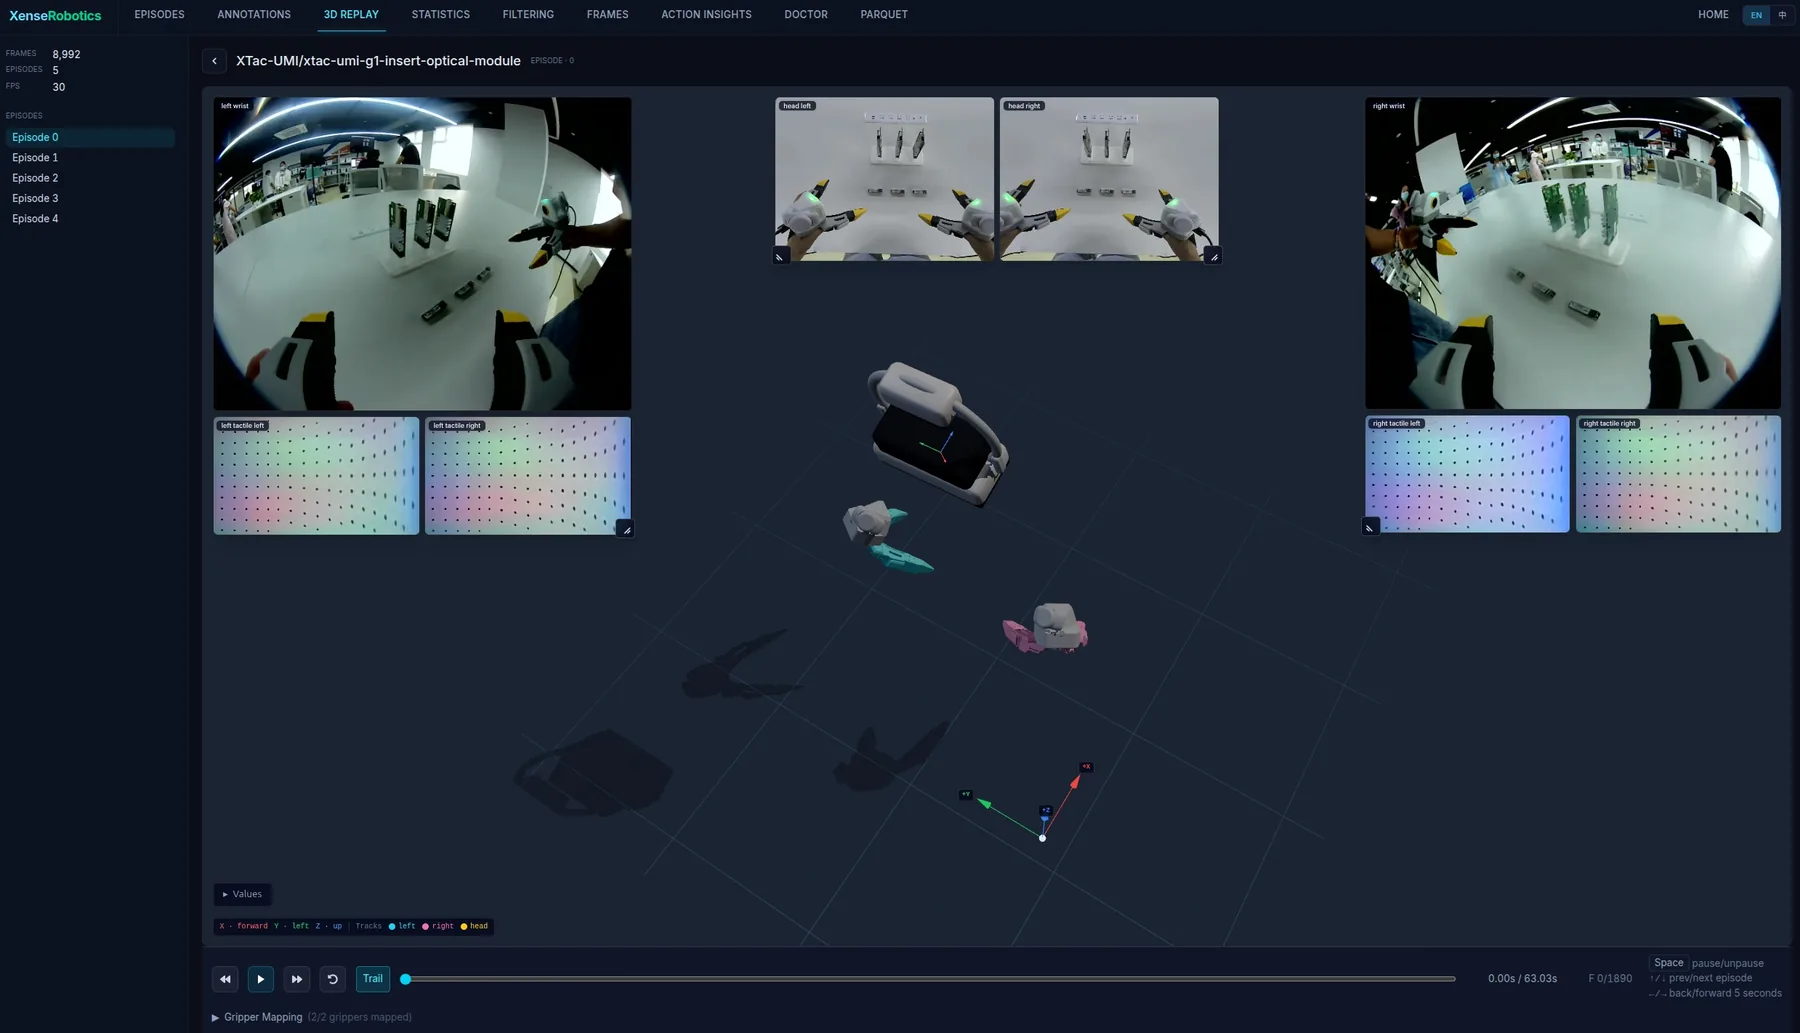
3 × 6-DoF poses both grippers + head
5ms sync positioning < 3mm
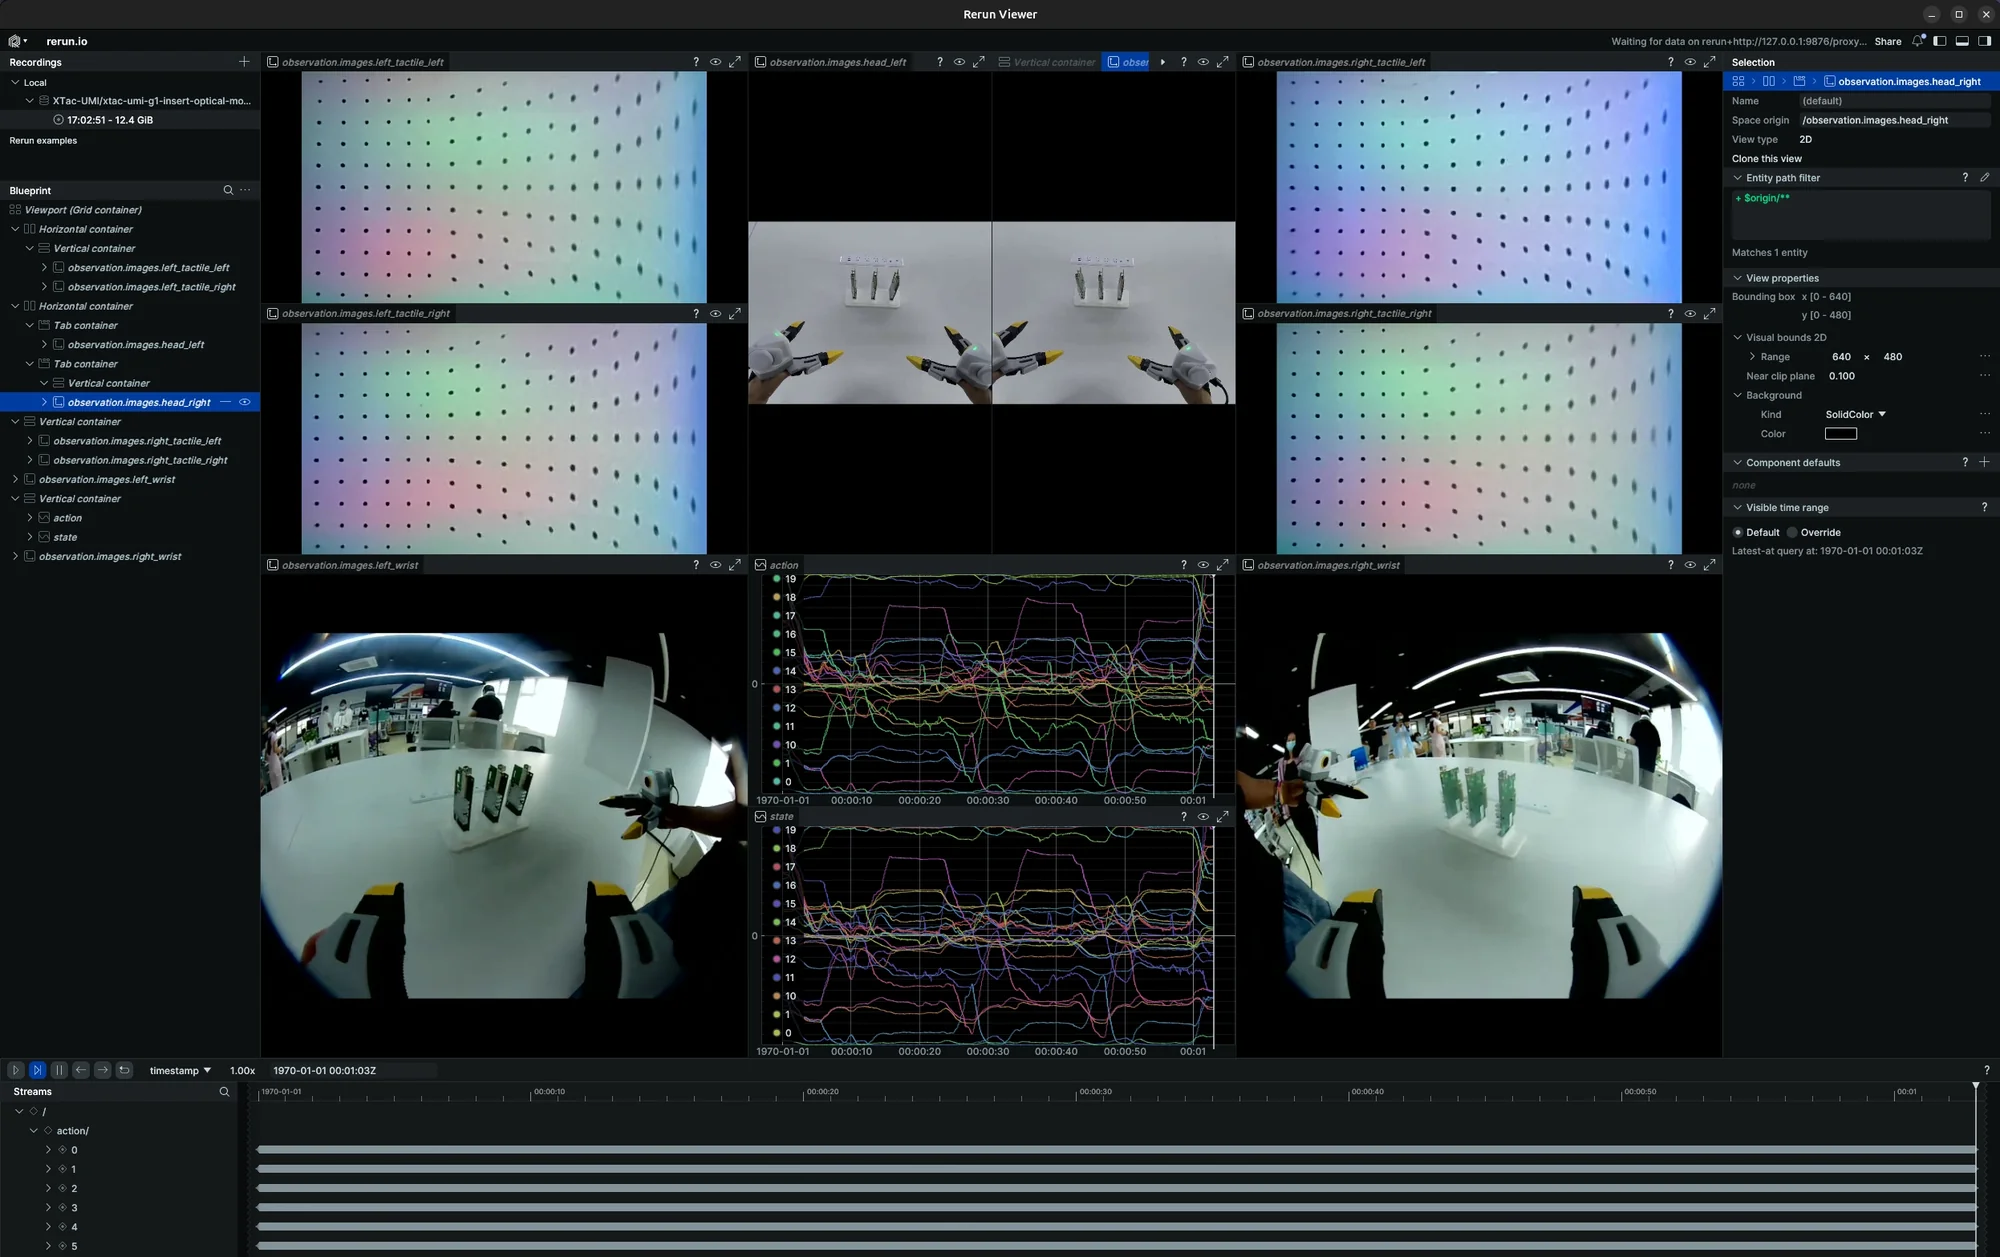
MCAP · LeRobotDataset v3 raw and training formats
Highlights
- Visuotactile fusion: tri-color fingertip sensors capture contact location, grasp stability and slip
- Close to the hand: the wearable leader handles grasping, insertion and thin-part picking
- Precise sync: 5ms multi-device time sync, < 3mm positioning
- Open formats: LeRobot / MCAP output, compatible with mainstream data ecosystems
Two editions for different settings
Both editions use the same grippers and headset and produce the same data. The Backpack Kit is a turnkey unit whose collection software is not open source; the Developer Kit's collection software and gripper SDK are open source and free to customize.
-
Backpack Kit
XTac UMI Backpack
- The backpack runs all collection; no computer needed
- A tablet browser is the console; gripper buttons start and stop recording
- One person wears it, suited to field work and long sessions
- Upload datasets to ModelScope in one click, as MCAP or LeRobotDataset v3
Turnkey, closed-source collection software; for large-scale collection teams and data factories
-
Developer Kit
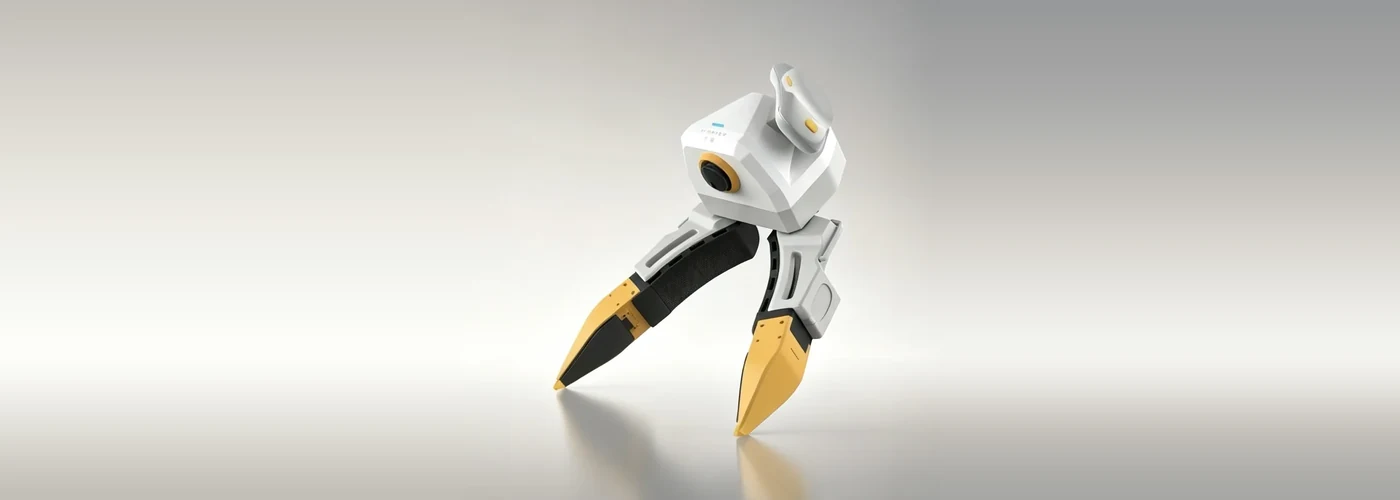
XTac UMI G1 Developer Kit (open source)
- Grippers and headset connect straight to your collection PC
- Built on open-source LeRobot; recording produces a LeRobotDataset
- Open-source collection software and gripper SDK, free to customize
- Supports the follower gripper for executing and replaying motions on a robot
For research and algorithm teams with their own training pipelines
The data you get
Open dataset: TacVerse
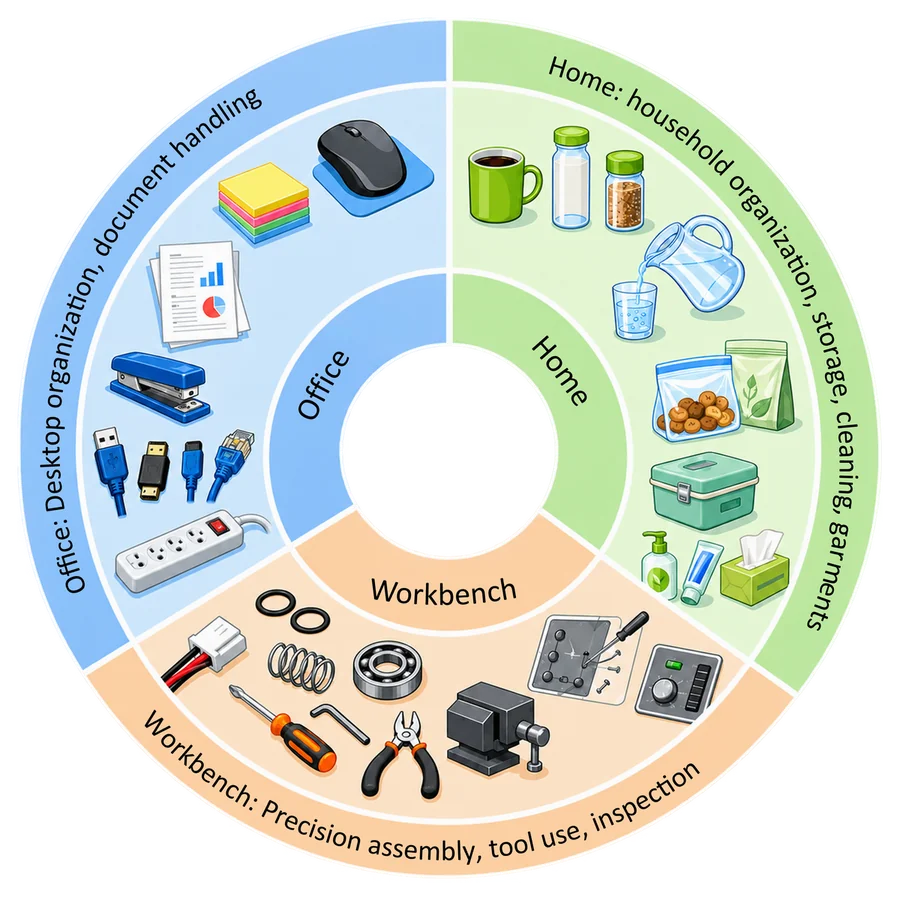
Visuotactile manipulation data collected with XTac UMI G1 grippers, released as LeRobotDataset v3 under CC BY-SA 4.0 and ready to download and train on.
- 122 tasks across office, home and workbench scenes
- 17,690 demonstrations: 370 hours, about 40 million frames
- Two-handed touch: four tactile streams, two wrist views and gripper poses per frame
Developer Kit open-source repositories
The Developer Kit's collection repo, gripper SDK, tracker service and viewer are open source under Apache-2.0, see the list; the Backpack Kit's software is closed.