XTac UMI G1
Xense XTac UMI G1 is a wearable data-collection gripper system for building embodied manipulation datasets. The leader gripper integrates tri-color visuotactile sensors, a wrist fisheye camera and a high-precision pose sensor, capturing vision, touch, pose, gripper state and IMU data in sync; the follower gripper mounts on the robot's end effector to execute or replay motions. The system serves imitation learning, VLA / VTLA model training and tactile world model research.
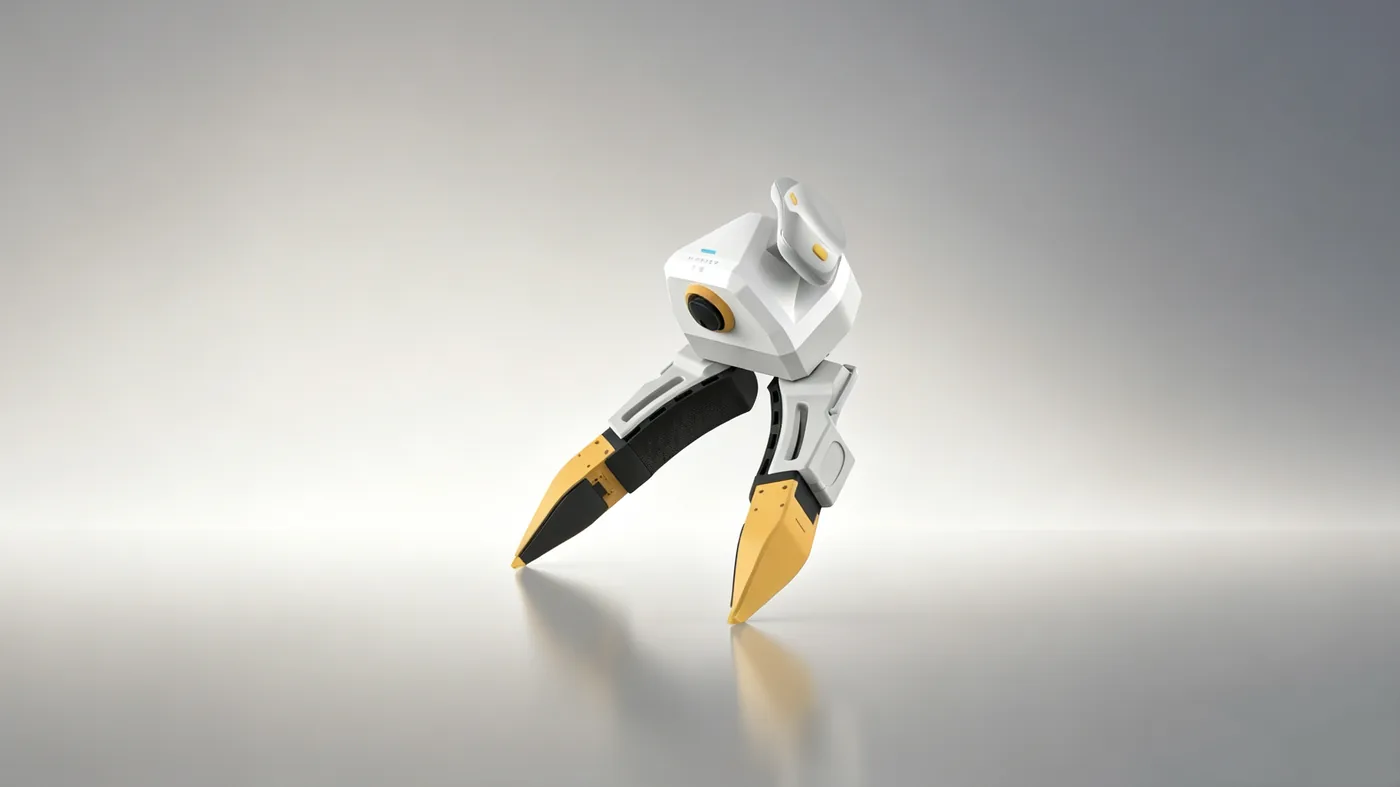
System components
| Part | Role |
|---|---|
| Leader grippers ×2 (left / right) | Handheld demonstration; each carries two visuotactile sensors, a wrist fisheye camera, an opening encoder and an IMU, see Gripper connection and serial numbers |
| Pico4 Ultra Enterprise trackers ×2 | Mounted on top of the leader grippers, giving their 6-DoF pose |
| Pico4 Ultra Enterprise headset | Tracks the trackers and sets the world frame; can also record a first-person stereo view, see Pico4 headset and tracker setup |
| Collection unit | The backpack on the Backpack Kit, your own collection PC on the Developer Kit, see Product line and configuration comparison |
| Follower grippers (optional) | Mounted on a robot to execute or replay motions, see Follower gripper overview |
Specifications are in Technical specifications.
Data flow
The sensor side is identical in both editions; they differ only from the collection unit onward. Hover over (or tap) any block to see where its data comes from and where it goes.
Backpack Kit
Recording is controlled by gripper button gestures; the gesture table is in Buttons.
Developer Kit
Key differences between the editions
| Backpack Kit | Developer Kit | |
|---|---|---|
| Preview | Browser console, a tablet is enough | Rerun window |
| Recording control | Mainly the gripper buttons; the console works too | lerobot-record command line |
| On disk | One MCAP raw recording per episode | LeRobotDataset v3 directly |
| Data out | Export per task as LeRobotDataset v3 / MCAP, upload to ModelScope in one click | Push to the Hugging Face Hub |
| Open source | No | Yes (Apache-2.0) |
Both editions record poses in the same coordinate frame, see Coordinate frames. The full comparison, box contents and wiring are in Product line and configuration comparison.
Next steps
- Wiring and serial numbers: Gripper connection and serial numbers; the Backpack Kit's buttons and LEDs: Gripper buttons, LEDs and voice
- Size, weight, sensors and backpack ports: Technical specifications
- Power and operating safety: Safety and compliance