Highlights
XTac UMI G1 is a multimodal UMI data-collection gripper whose fingertips carry Xense's own visuotactile sensors, seeing exactly where, how hard and how stably every contact happens. A handheld demonstration records touch, vision and pose in sync, turning out high-quality robot manipulation data for imitation learning, VLA model training and tactile research.
Core value
-
Lower cost, shorter data path
Capture, synchronization and tooling live in one system, turning human demonstrations straight into trainable data.
-
Natural handling, efficient collection
The wearable form follows the hand's own motion, is quick to learn, and suits long, multi-task sessions.
-
From "watchable" to "understandable" data
Beyond recording that "the hand moved", it tells whether, where and how stably contact happened.
-
Traceable data at scale
Standardized output and fleet deployment; data is easy to review, compare and reuse.
Six highlights
-
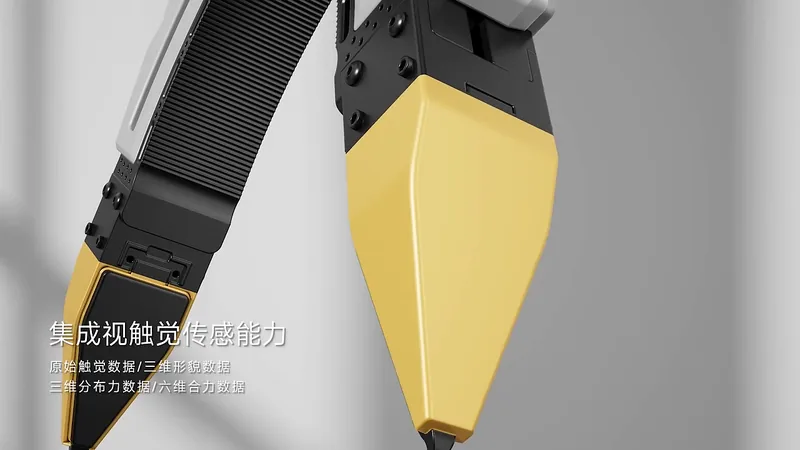
Visuotactile fusion, real interaction
High-frame-rate tri-color visuotactile sensors record contact location, grasp stability and slip trends in sync.
-
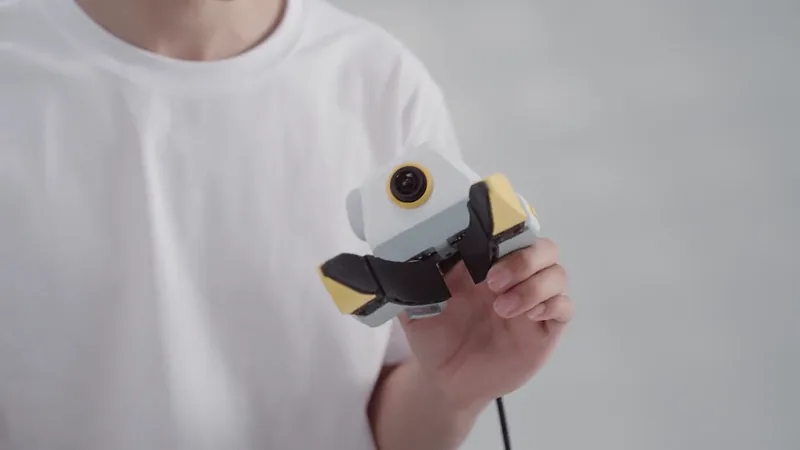
Close to the human hand, faster collection
The wearable leader gripper is light and easy to pick up, covering grasping, carrying, insertion, thin-part picking and more.
-
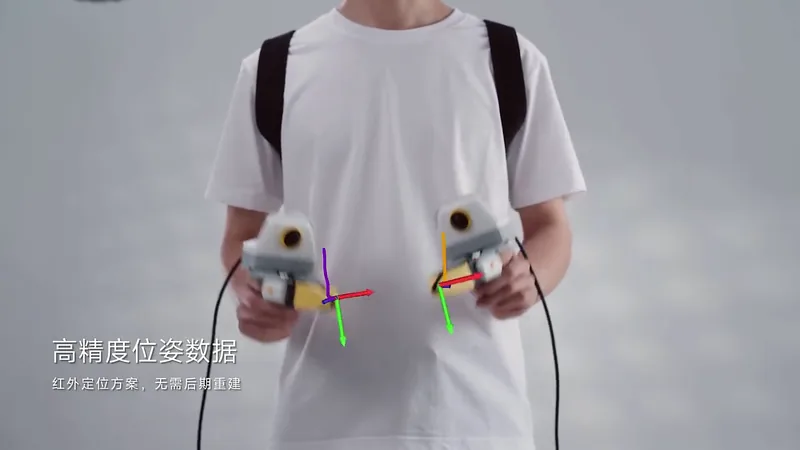
High-precision pose, high-quality data
Multi-device time sync of 5ms and positioning accuracy of < 3mm; every stream is aligned to the same instant.
-
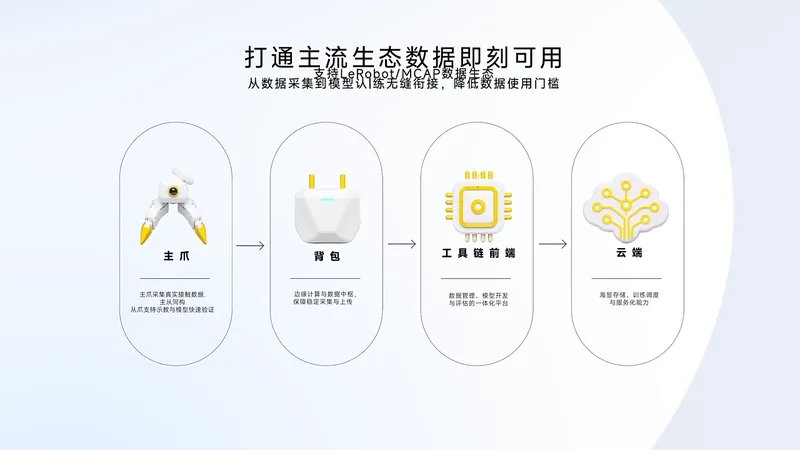
Mainstream ecosystem, data ready to use
Native support for LeRobot, MCAP and other mainstream formats and tools, so data is ready for training as soon as it is collected.
-
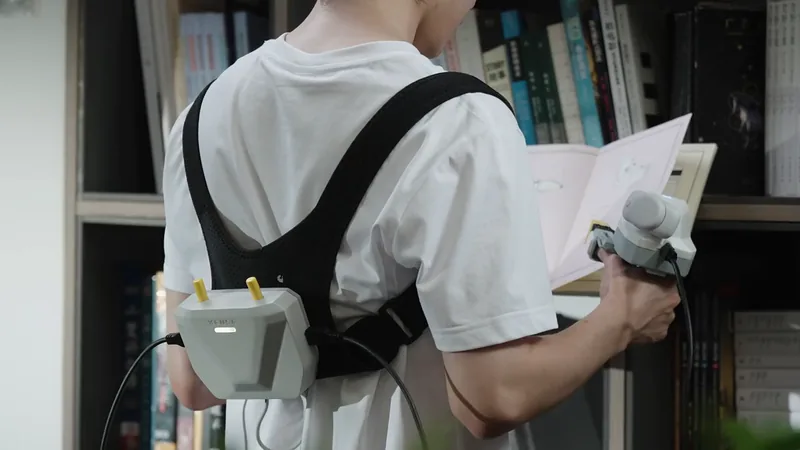
Light deployment, built for scale
A light leader gripper and a wearable collection unit, ready for the lab, home or field.
-
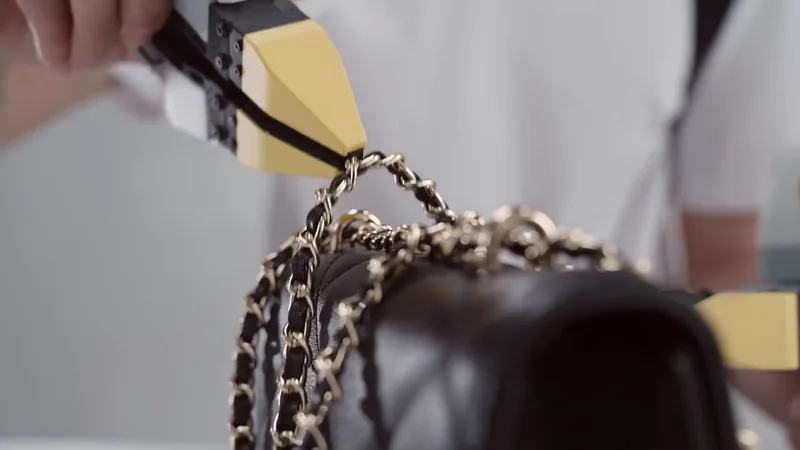
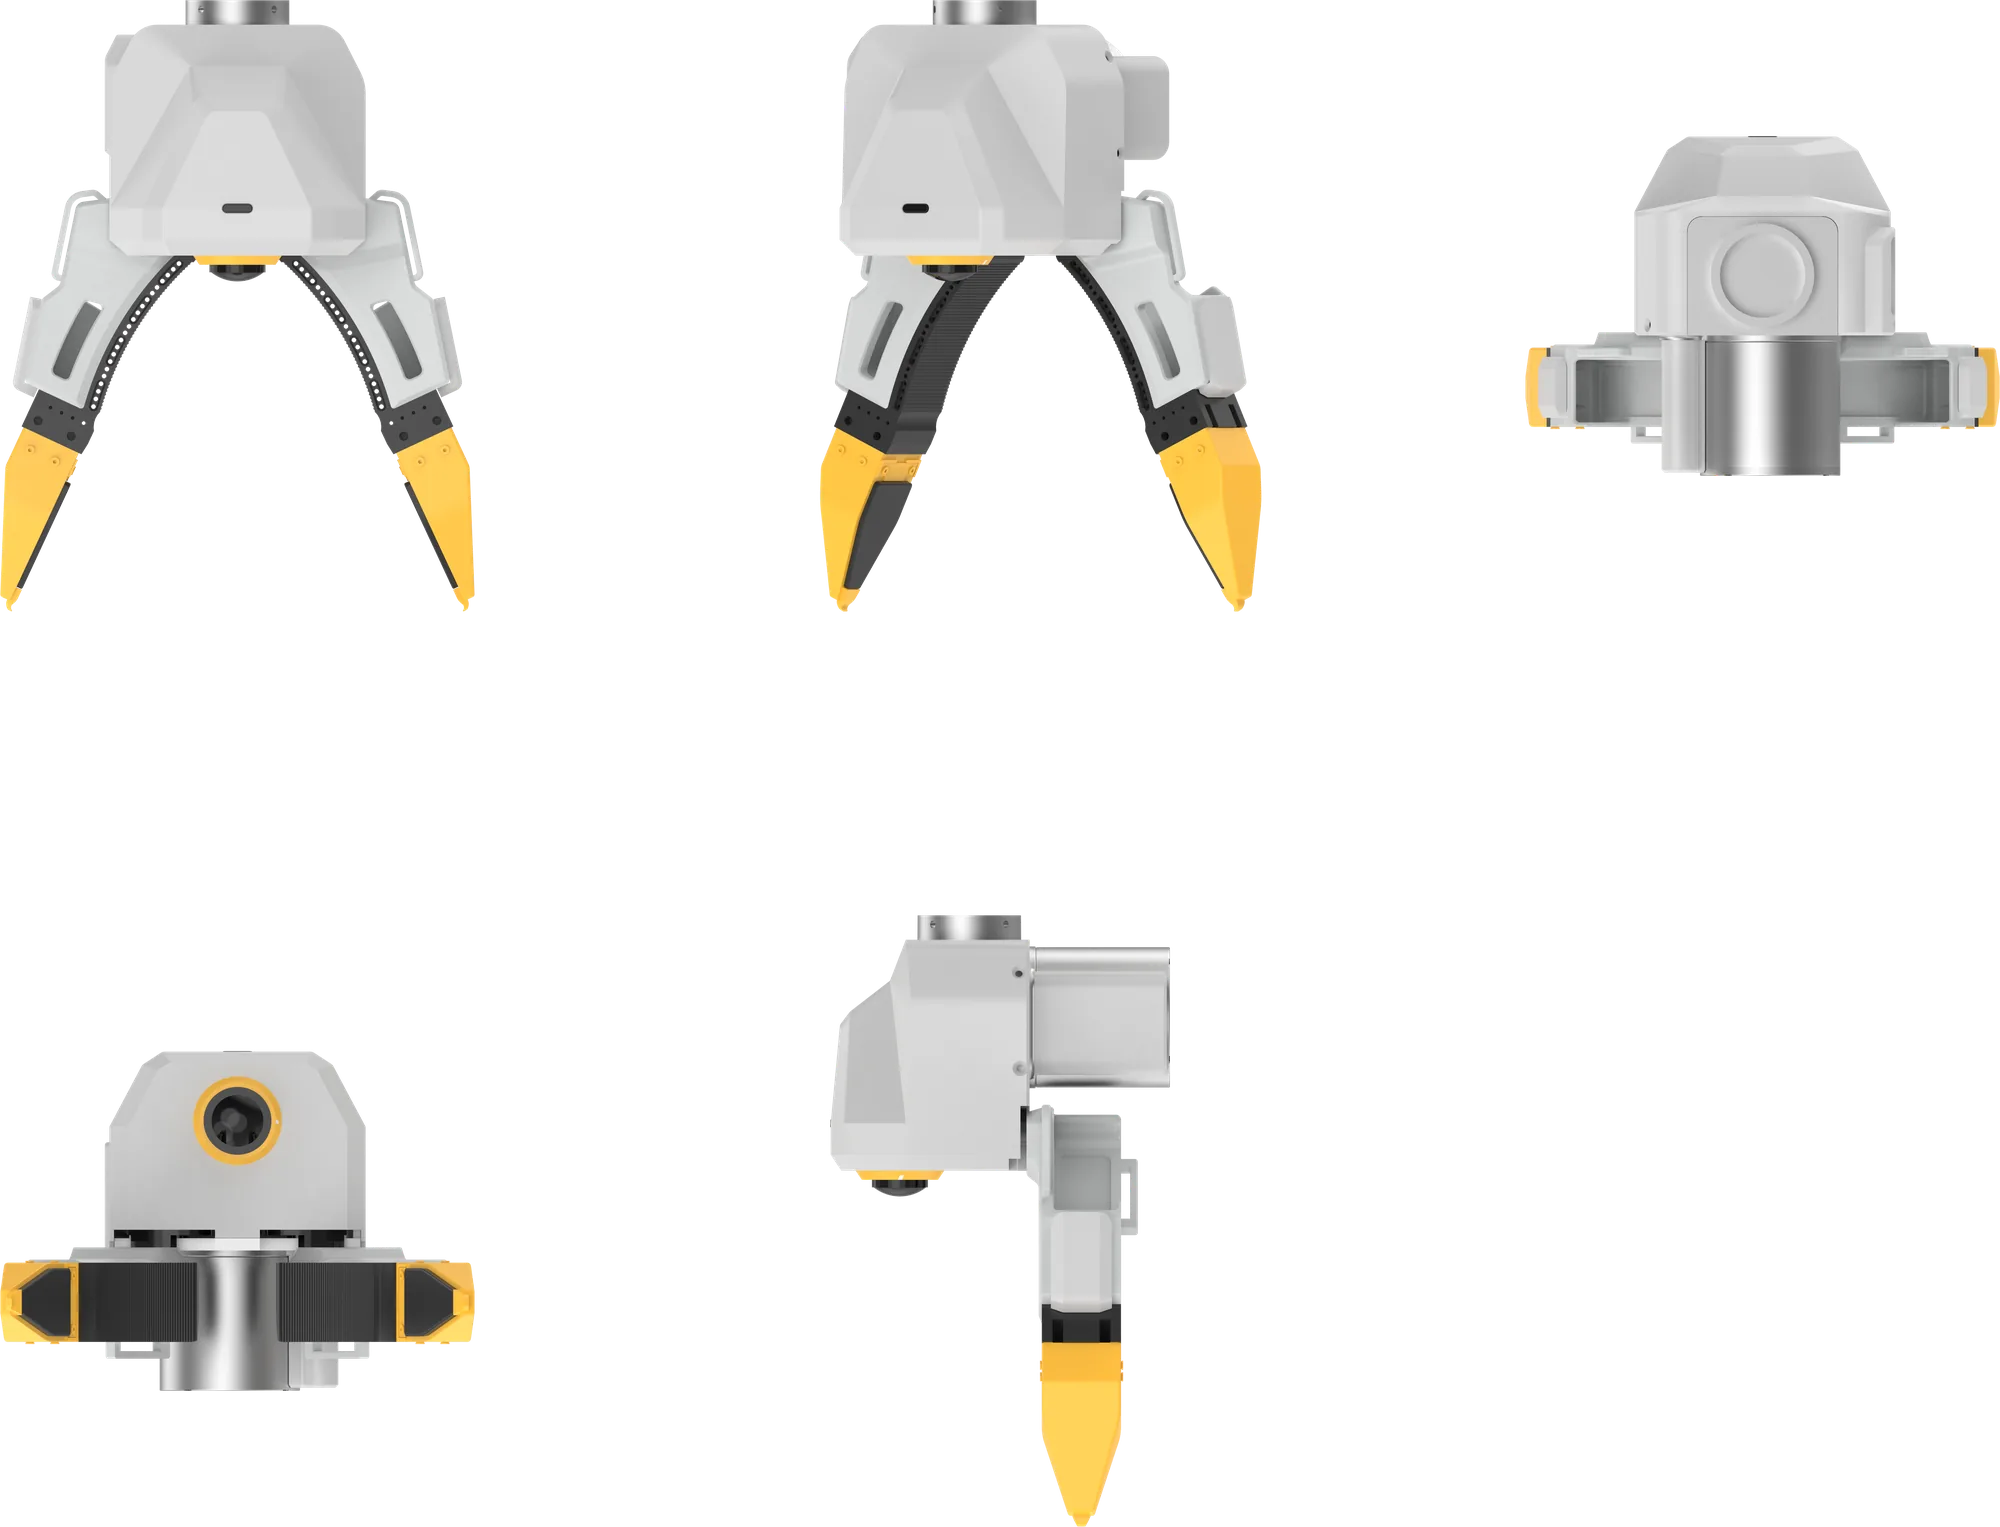
Compliant fingertips for fine grasping
Slim, compliant fingertips make small parts, thin sheets and edge-lying objects easier to pick up.
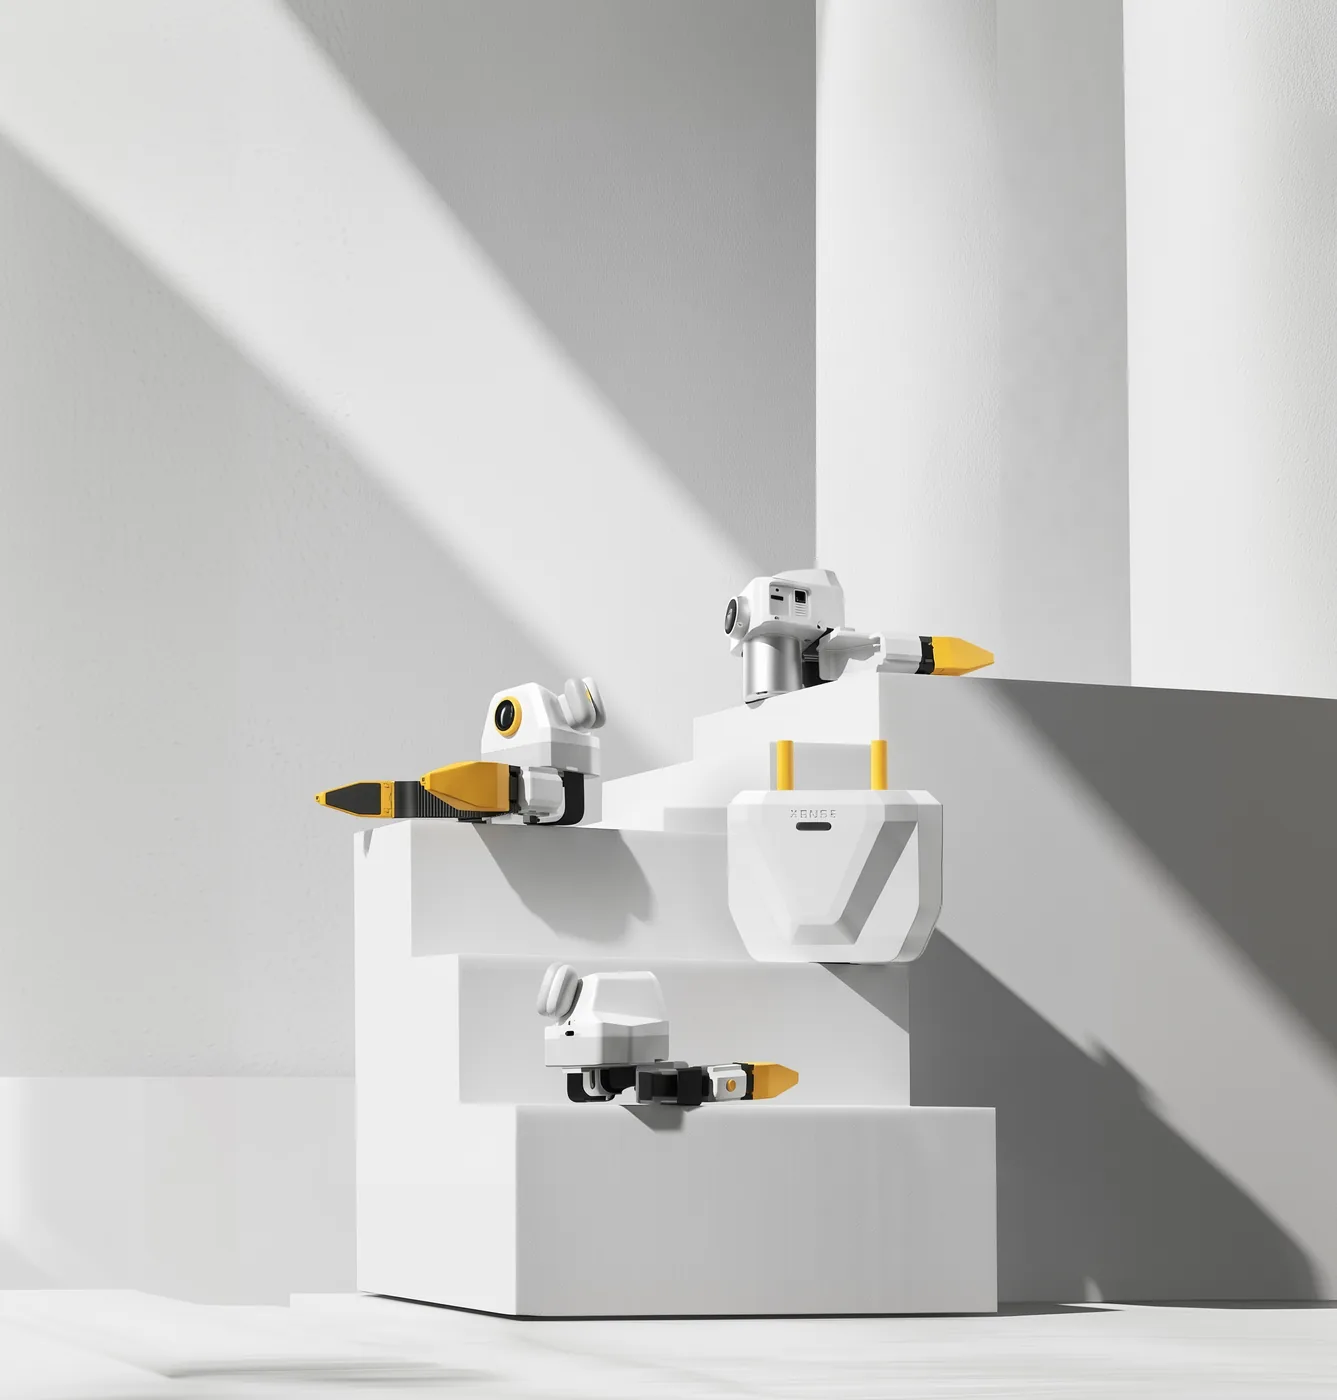
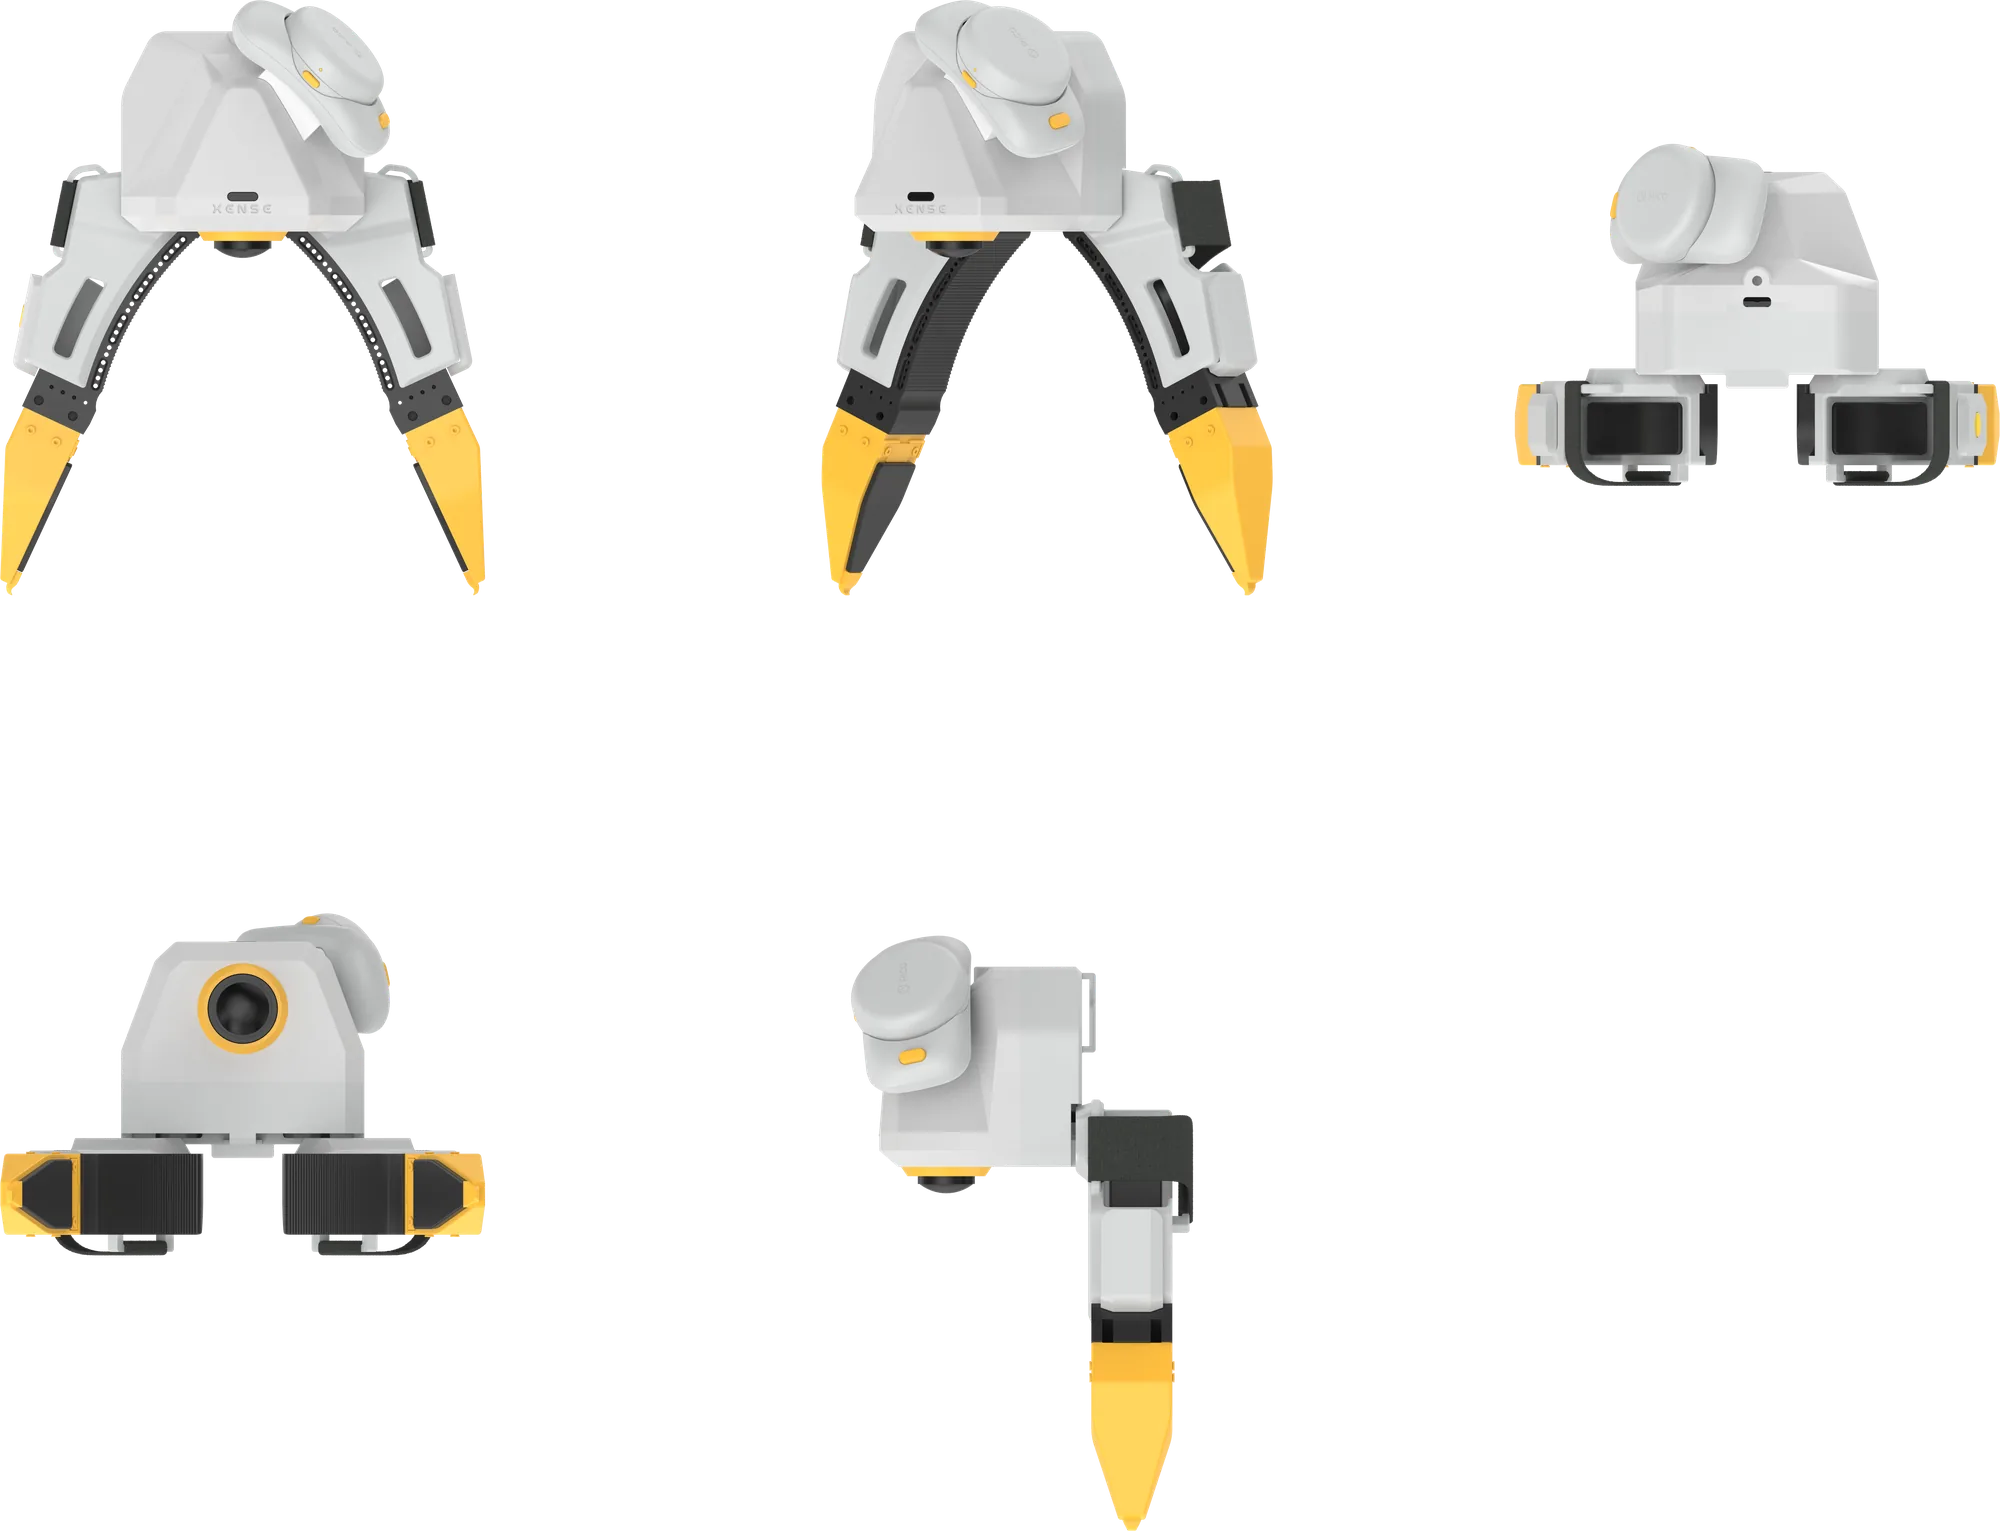
Product appearance
Applications
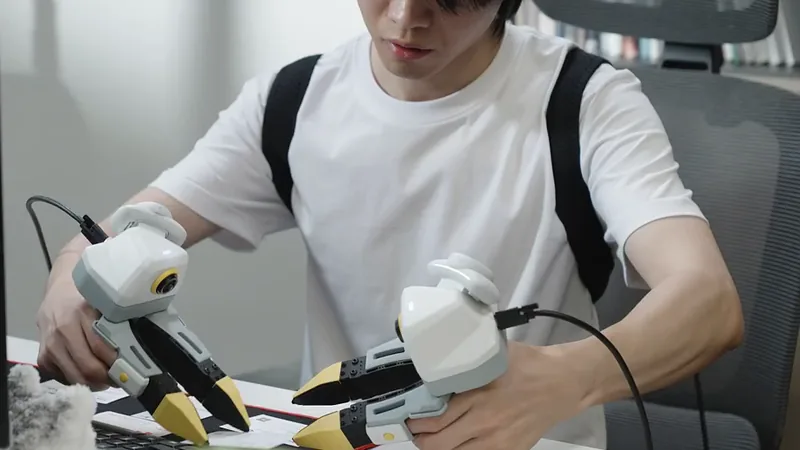
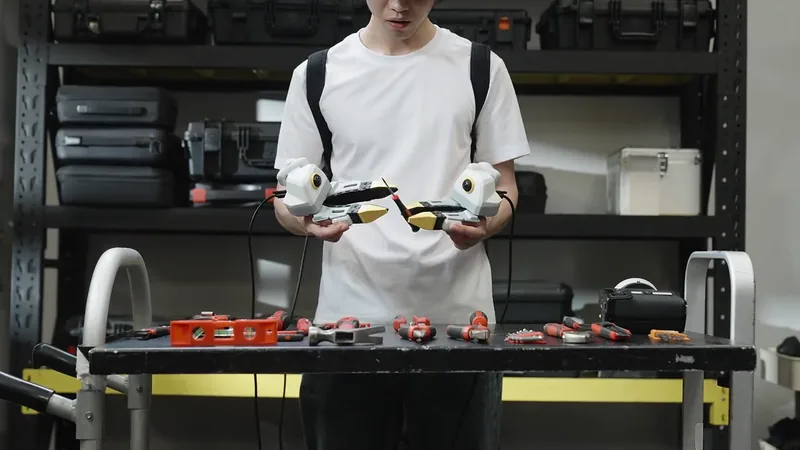
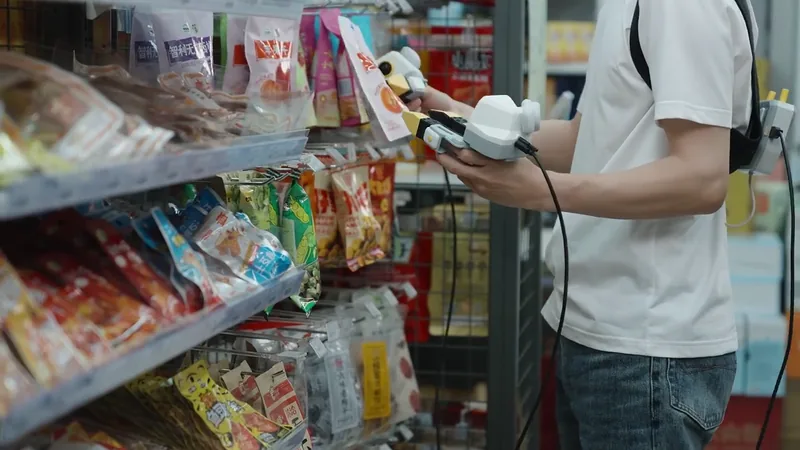
- Embodied-AI data factories: large-scale manipulation data collection across many stations, operators and tasks.
- Robot algorithm R&D: a source of real interaction data for robotics companies, university labs and embodied-AI teams.
- Home and service robots: tidying desks, picking and placing items, opening containers, using tools.
- Flexible industrial manipulation: 3C assembly, small-part sorting, cable insertion, part picking.
- Tactile and real-interaction research: contact-state understanding, tactile representation and tactile foundation models.
Full specifications
Product parameters are in Technical specifications.